Particle Image Velocimetry analysis with OpenPIV
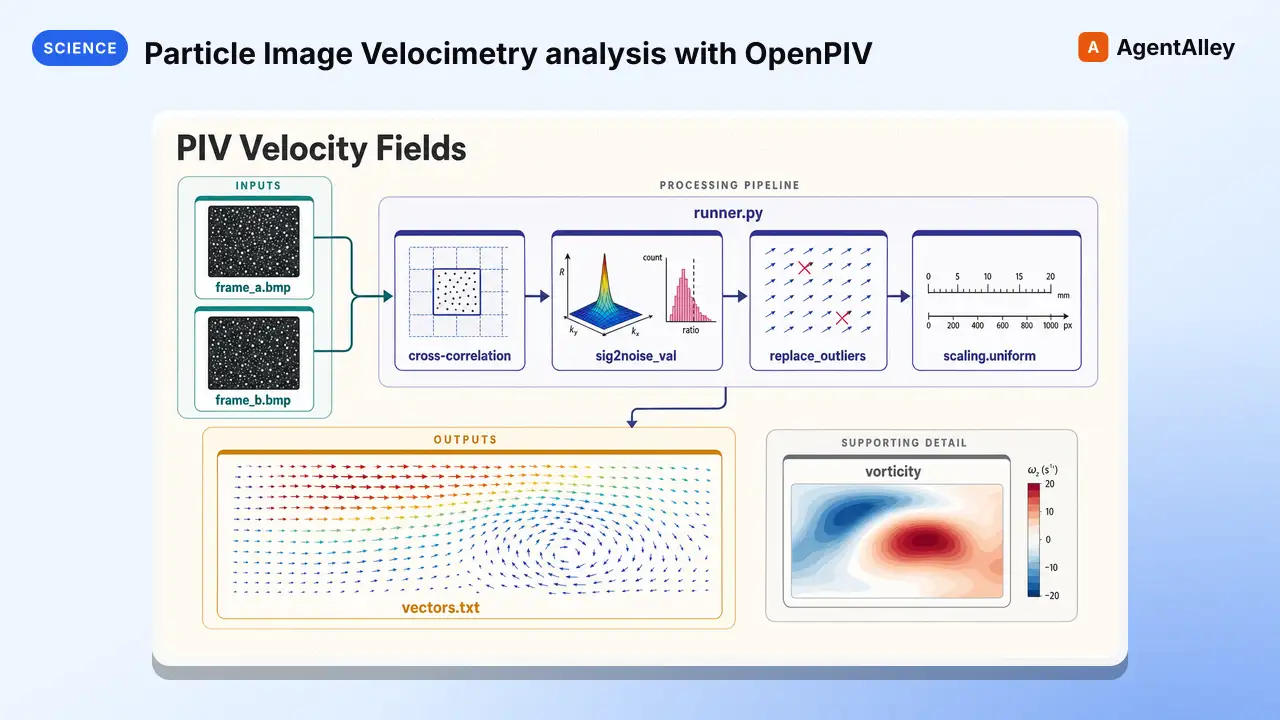
Particle Image Velocimetry (PIV) analysis with OpenPIV. Use when extracting velocity fields from PIV image pairs, analyzing fluid dynamics or flow visualization experiments, cross-correlating interrogation windows, validating and…
---
name: openpiv
description: Particle Image Velocimetry (PIV) analysis with OpenPIV. Use when extracting velocity fields from PIV image pairs, analyzing fluid dynamics or flow visualization experiments, cross-correlating interrogation windows, validating and replacing spurious PIV vectors, or computing vorticity, strain rate, and turbulence statistics from measured velocity fields.
license: BSD-3-Clause
compatibility: Requires Python 3.10+ with openpiv installed (uv pip install openpiv). numpy, scipy, scikit-image, and matplotlib arrive as dependencies. No network access needed after install.
allowed-tools: Read Write Edit Bash
metadata:
  version: "1.1"
  skill-author: OpenPIV Team
  tested-against: "openpiv 0.25.4"
---

# OpenPIV

## Overview

OpenPIV (Open Particle Image Velocimetry) analyzes fluid flow from PIV image pairs. It covers
preprocessing, cross-correlation, vector validation, outlier replacement, smoothing, and scaling to
Overview
OpenPIV (Open Particle Image Velocimetry) analyzes fluid flow from PIV image pairs. It covers preprocessing, cross-correlation, vector validation, outlier replacement, smoothing, and scaling to physical units.
What you get
- vectors.txttab-delimited, %.4e formatted, with a # x y u v flags mask comment header
- params.npzNumPy archive with x, y, u, v, flags arrays
- vector_field.pngvector field drawn over the first frame
Manual install (npx, ZIP)
npx skills add K-Dense-AI/scientific-agent-skills --skill openpiv -g -a claude-codemkdir -p ~/.claude/skills && curl -sL https://codeload.github.com/K-Dense-AI/scientific-agent-skills/tar.gz/49c6e97775ea \
| tar -xz -C ~/.claude/skills --strip-components=2 scientific-agent-skills-49c6e97775ea/skills/openpivNew-Item -ItemType Directory -Force "$HOME\.claude\skills" | Out-Null; Invoke-WebRequest "https://m.agentalley.io/zip/67214c3213d8dac1f14b/openpiv.zip" -OutFile "$env:TEMP\openpiv.zip"; Expand-Archive "$env:TEMP\openpiv.zip" -DestinationPath "$HOME\.claude\skills" -ForceConnects with Agent Alley MCP · agentalley.io/mcp
Files included
SKILL.md16.6 KBreferences/1 file · 10.4 KBscripts/4 files · 15.0 KB
Read the files here
K-Dense-AI/
Show the full text470 lines
OpenPIV
Overview
OpenPIV (Open Particle Image Velocimetry) analyzes fluid flow from PIV image pairs. It covers preprocessing, cross-correlation, vector validation, outlier replacement, smoothing, and scaling to physical units.
Everything below is verified against openpiv 0.25.4. The API moves between releases — check
inspect.signature() before trusting a snippet against a different version.
When to use
Use this skill when working with experimental PIV or flow-visualization image pairs: measuring 2D velocity fields, tuning interrogation-window parameters, validating vectors, or deriving vorticity, strain rate, and turbulence statistics. For simulating flow rather than measuring it, use a CFD skill instead.
Quick Start
Install OpenPIV:
uv pip install openpiv

# Pin it when the analysis needs to be reproducible -- this is the version every
# snippet below was checked against.
uv pip install "openpiv==0.25.4"
Run PIV analysis on an image pair:
import numpy as np
from openpiv import tools, pyprocess, validation, filters, scaling

frame_a = tools.imread("image_a.bmp")
frame_b = tools.imread("image_b.bmp")

# Cross-correlate. Returns (u, v, s2n) whenever sig2noise_method is not None.
u, v, s2n = pyprocess.extended_search_area_piv(
    frame_a.astype(np.int32),
    frame_b.astype(np.int32),
    window_size=32,
    overlap=12,
    dt=0.02,
    search_area_size=38,
    correlation_method="linear",   # required for search_area_size > window_size
    sig2noise_method="peak2peak",
)

x, y = pyprocess.get_coordinates(
    image_size=frame_a.shape,
    search_area_size=38,
    overlap=12,
)

# flags is a boolean array: True marks a spurious vector.
flags = validation.sig2noise_val(s2n, threshold=1.05)
u, v = filters.replace_outliers(u, v, flags, method="localmean", max_iter=3, kernel_size=2)

# Scale to physical units, then flip to image coordinates for plotting.
x, y, u, v = scaling.uniform(x, y, u, v, scaling_factor=96.52)
x, y, u, v = tools.transform_coordinates(x, y, u, v)

tools.save("vectors.txt", x, y, u, v, flags)
Or use the bundled CLI, which wraps exactly that pipeline:
python skills/openpiv/scripts/runner.py \
    --image frame_a.bmp --image frame_b.bmp --output_dir results --verbose
Core Concepts
PIV Fundamentals
Particle Image Velocimetry is an optical method for measuring fluid velocity by tracking illuminated tracer particles between two images.
Process flow:
- Capture an image pair (
frame_a,frame_b) separated by a known timedt. - Divide the images into interrogation windows.
- Cross-correlate matching windows to find peak displacement.
- Validate vectors (signal-to-noise, global range, local median).
- Replace spurious vectors with interpolated values.
- Scale pixel displacements to physical units.
Interrogation Window Parameters
window_size — correlation window in pixels (typically 16–128). Larger windows give better
correlation but coarser spatial resolution.
overlap — pixels shared between adjacent windows (typically 50–75% of window_size). Higher
overlap raises vector density and cost, but adjacent vectors become correlated rather than
independent.
search_area_size — the window searched in the second frame. Must be ≥ window_size; a few
pixels larger accommodates larger displacements. Pair an extended search area with
correlation_method="linear" — the default "circular" relies on FFT wrap-around and aliases large
displacements into small ones. See references/advanced_algorithms.md.
Rules of thumb: keep the largest displacement under about a quarter of window_size, and aim for
5–10 particles per window.
Signal-to-Noise Ratio
s2n measures how distinct the correlation peak is. sig2noise_method controls how it is computed —
"peak2mean" (the function default) or "peak2peak". The two are on different scales, so a
threshold tuned for one is meaningless for the other. Typical peak2peak thresholds are 1.05–1.3.
flags = validation.sig2noise_val(s2n, threshold=1.05)
# flags is bool: True == spurious. `~flags` selects the good vectors.
Common Operations
Dynamic Masking
Masking lives in openpiv.preprocess, not in an openpiv.masking module. It returns an
(image, mask) tuple and expects a float image.
from openpiv import preprocess

# method="edges" for dark, sharp-edged objects; "intensity" for high-contrast objects.
frame_a_masked, mask_a = preprocess.dynamic_masking(
    frame_a.astype(np.float64), method="intensity", filter_size=7, threshold=0.005
)
frame_b_masked, mask_b = preprocess.dynamic_masking(
    frame_b.astype(np.float64), method="intensity", filter_size=7, threshold=0.005
)
Feed the returned image into the correlation step — it already has the masked region zeroed. Do
not multiply the original frame by mask: masking is already applied, and for method="edges" the
mask comes back as uint8 0/255 rather than boolean, so multiplying rescales the image by 255.
Multi-Pass Processing
Multi-pass (window deformation) lives in openpiv.windef, driven by a PIVSettings dataclass.
pyprocess has no multi-pass entry point.
import numpy as np
from openpiv import scaling, windef

settings = windef.PIVSettings()
settings.windowsizes = (64, 32, 16)   # one entry per pass, decreasing (this is also the default)
settings.overlap = (32, 16, 8)        # same length as windowsizes
settings.num_iterations = 3           # number of passes to actually run
settings.sig2noise_threshold = 1.05

x, y, u, v, flags = windef.simple_multipass(
    frame_a.astype(np.int32), frame_b.astype(np.int32), settings
)

# Output is in PIXELS PER FRAME -- convert yourself. scaling.uniform only divides
# by scaling_factor, so apply dt separately.
dt = 0.02
x, y, u, v = scaling.uniform(x, y, u, v, scaling_factor=96.52)
u, v = u / dt, v / dt
simple_multipass already validates, replaces outliers, fills remaining NaNs with zeros, and calls
transform_coordinates — do not repeat those steps.
Units trap: PIVSettings has dt and scaling_factor fields, but windef never uses either —
first_pass calls extended_search_area_piv without dt, so the whole multi-pass chain works in
pixels per frame. Setting settings.dt = 0.02 changes nothing about the returned values. Convert
after the fact, as above.
For control over individual passes, windef.first_pass and windef.multipass_img_deform are the
lower-level building blocks.
Validation and Post-Processing
Validation Methods
Every validator returns a boolean array where True marks a spurious vector.
# Signal-to-noise
flags = validation.sig2noise_val(s2n, threshold=1.05)

# Global range -- takes (min, max) TUPLES, positionally or as u_thresholds/v_thresholds.
flags = validation.global_val(u, v, (-300, 300), (-300, 300))

# Local median -- u_threshold and v_threshold are REQUIRED; size is the neighbourhood half-width.
flags = validation.local_median_val(u, v, u_threshold=30.0, v_threshold=30.0, size=1)

# Combine with boolean OR (not np.maximum -- these are bool arrays).
flags = (
    validation.sig2noise_val(s2n, threshold=1.05)
    | validation.global_val(u, v, (-300, 300), (-300, 300))
    | validation.local_median_val(u, v, u_threshold=30.0, v_threshold=30.0)
)
Set these thresholds in the units of u and v, not in pixels per frame.
extended_search_area_piv divides by dt, so with dt=0.02 a 3 px/frame displacement arrives as
150 px/s. The thresholds above suit that case; the (-30, 30) figure that PIV literature and
PIVSettings.min_max_u_disp use is a px/frame limit, and applying it to px/s output rejects the
entire field. Either validate before scaling, or scale the thresholds by 1/dt too.
Outlier Replacement
u, v = filters.replace_outliers(
    u, v, flags, method="localmean", max_iter=3, tol=1e-3, kernel_size=2
)
method accepts "localmean", "disk", or "distance" — and only those three. An unrecognized
name is not rejected; it falls through to an all-zero kernel and silently returns a useless field.
Note that replacement fills the flagged
positions with interpolated values — if you then overwrite them with NaN, the replacement was
wasted. Choose one or the other:
# Keep flagged vectors out of the analysis entirely, instead of interpolating them.
u = np.where(flags, np.nan, u)
v = np.where(flags, np.nan, v)
Smoothing
Smoothing is openpiv.smoothn.smoothn; there is no openpiv.smooth module. It returns a tuple
whose first element is the smoothed field, and it does not accept NaN input.
from openpiv.smoothn import smoothn

u_smooth, *_ = smoothn(np.nan_to_num(u), s=0.5)  # s: larger == smoother
v_smooth, *_ = smoothn(np.nan_to_num(v), s=0.5)
u_smooth = np.asarray(u_smooth)
Visualization
Vector Field Plotting
display_vector_field reads a saved vectors file and calls plt.show() internally, so select a
non-interactive backend for batch runs.
import matplotlib
matplotlib.use("Agg")
import matplotlib.pyplot as plt
from openpiv import tools

fig, ax = plt.subplots(figsize=(8, 8))
tools.display_vector_field(
    "vectors.txt",
    ax=ax,
    scaling_factor=96.52,   # same factor used in scaling.uniform, to map back onto the image
    scale=50,
    width=0.0035,
    on_img=True,
    image_name="frame_a.bmp",
)
fig.savefig("vector_field.png", dpi=150, bbox_inches="tight")
plt.close(fig)
Custom Visualization
import numpy as np
import matplotlib.pyplot as plt

fig, axes = plt.subplots(1, 3, figsize=(15, 5))

mag = np.sqrt(u**2 + v**2)
for ax, field, title, cmap in [
    (axes[0], mag, "Velocity Magnitude", "viridis"),
    (axes[1], u, "U Velocity", "RdBu_r"),
    (axes[2], v, "V Velocity", "RdBu_r"),
]:
    im = ax.imshow(field, cmap=cmap)
    ax.set_title(title)
    plt.colorbar(im, ax=ax)

fig.tight_layout()
fig.savefig("velocity_components.png")
plt.close(fig)
Analysis Functions
scripts/analyze.py bundles these against a params.npz written by runner.py. It infers the
physical grid spacing from the saved coordinates, so the derivatives come out per unit length:
import sys
sys.path.insert(0, "skills/openpiv/scripts")
from analyze import PIVAnalyzer

piv = PIVAnalyzer("results/params.npz")
vorticity = piv.compute_vorticity()          # dv/dx - du/dy
exx, eyy, exy = piv.compute_strain()
stats = piv.compute_statistics()             # u_mean, v_mean, rms_u, rms_v, tke
piv.plot_vector_field(save_path="quiver.png")
The standalone forms, if you would rather compute them inline:
Vorticity
def compute_vorticity(u, v, dx=1.0, dy=None):
    """Out-of-plane vorticity dv/dx - du/dy. Pass the physical grid spacing, not 1.0."""
    dy = dx if dy is None else dy
    return np.gradient(v, dx, axis=1) - np.gradient(u, dy, axis=0)
The grid spacing is (window_size - overlap) / scaling_factor in physical units, so leaving dx=1.0
yields vorticity per grid cell, not per unit length.
Sign convention: runner.py ends with transform_coordinates, which relabels the grid into a
right-handed y-up frame but leaves the rows in image order, so the saved y decreases as the row
index grows. The standalone forms above assume the opposite, so on a params.npz field they return
-du/dy and flip the sign of the vorticity and the shear strain — negate the axis=0 derivatives, or
use PIVAnalyzer, which reads the orientation off the saved coordinates.
Strain Rate
def compute_strain(u, v, dx=1.0, dy=None):
    """Return (exx, eyy, exy) of the 2D strain-rate tensor."""
    dy = dx if dy is None else dy
    du_dx = np.gradient(u, dx, axis=1)
    du_dy = np.gradient(u, dy, axis=0)
    dv_dx = np.gradient(v, dx, axis=1)
    dv_dy = np.gradient(v, dy, axis=0)
    return du_dx, dv_dy, 0.5 * (du_dy + dv_dx)
Turbulence Statistics
def compute_statistics(u, v):
    """Single-frame spatial statistics. NOT Reynolds decomposition."""
    u_prime = u - np.nanmean(u)
    v_prime = v - np.nanmean(v)
    rms_u, rms_v = np.nanstd(u_prime), np.nanstd(v_prime)
    return {
        "u_mean": np.nanmean(u),
        "v_mean": np.nanmean(v),
        "rms_u": rms_u,
        "rms_v": rms_v,
        "tke": 0.5 * (rms_u**2 + rms_v**2),
    }
Caveat: subtracting the spatial mean of one frame measures spatial variance, which equals turbulent intensity only for a homogeneous field. Genuine Reynolds decomposition needs an ensemble of image pairs: average over the time axis, then subtract that mean field from each realization.
CLI Usage
# Basic run
python skills/openpiv/scripts/runner.py \
    --image img1.bmp --image img2.bmp --output_dir results --verbose

# Tuned parameters with dynamic masking
python skills/openpiv/scripts/runner.py \
    --image frame_a.bmp \
    --image frame_b.bmp \
    --output_dir results \
    --window_size 32 \
    --overlap 12 \
    --search_area 38 \
    --dt 0.02 \
    --scaling 96.52 \
    --threshold 1.05 \
    --mask dynamic \
    --mask_method intensity \
    --verbose
CLI Options
| Option | Default | Description |
|---|---|---|
--image |
required | Image file; specify exactly twice for the pair |
--output_dir |
results |
Output directory (created if absent) |
--window_size |
32 | Interrogation window size (px) |
--overlap |
12 | Window overlap (px) |
--search_area |
38 | Search area size (px), must be ≥ --window_size |
--dt |
0.02 | Time between frames (s) |
--scaling |
96.52 | Scaling factor, pixels per physical unit (e.g. px/mm) |
--threshold |
1.05 | peak2peak signal-to-noise threshold |
--mask |
none |
none or dynamic (openpiv.preprocess.dynamic_masking) |
--mask_method |
intensity |
edges or intensity, used only with --mask dynamic |
--drop_invalid |
off | NaN out flagged vectors instead of keeping interpolated values |
--verbose |
off | Print progress messages |
Verify an install end to end against OpenPIV's own bundled image pair:
python skills/openpiv/scripts/run_example.py --output_dir /tmp/openpiv-demo
Output Files
- vectors.txt — tab-delimited,
%.4eformatted, with a# x y u v flags maskcomment header - params.npz — NumPy archive with
x,y,u,v,flagsarrays - vector_field.png — vector field drawn over the first frame
# x	y	u	v	flags	mask
2.1757e-01	3.5226e+00	-6.2220e-02	-2.7081e+00	0.0000e+00	0.0000e+00
4.8695e-01	3.5226e+00	-3.1587e-01	-2.9800e+00	0.0000e+00	0.0000e+00
flags is written as a float, 0 for a valid vector and 1 for a flagged one.
Best Practices
Parameter Selection
- Window size — 32×32 suits most cases. 64/128 for better correlation at coarser resolution; 16/24 for finer resolution at the cost of noise.
- Overlap — 50–75% of window size.
- Threshold — raise it to reject more vectors; always re-tune after switching
sig2noise_method. - Scaling factor — calibrate against a known reference such as a calibration grid, and keep the
units straight (
96.52in OpenPIV'stest1tutorial data is px/mm).
Image Quality
- Particles visible and evenly distributed, 5–10 per interrogation window
- No saturated or overexposed regions
- Minimal background noise; consider background subtraction across a run
Processing Tips
- Start from the defaults, then tune against the vector field you get.
- Inspect the
s2ndistribution — a low median means poor correlation, not a bad threshold. - Visualize early; obvious problems (uniform vectors, edge artifacts) show up immediately.
- Use multi-pass (
windef) for flows with large velocity gradients or displacements. - Mask reflections and solid boundaries rather than letting them generate vectors.
Resources
references/
advanced_algorithms.md— correlation and subpixel methods, multi-pass window deformation,PIVSettingsfields, 3D and phase-separation modules
Load the reference when detailed algorithm or settings information is needed.
| 1 | |
| 2 | name openpiv |
| 3 | description Particle Image Velocimetry (PIV) analysis with OpenPIV. Use when extracting velocity fields from PIV image pairs, analyzing fluid dynamics or flow visualization experiments, cross-correlating interrogation windows, validating and replacing spurious PIV vectors, or computing vorticity, strain rate, and turbulence statistics from measured velocity fields. |
| 4 | license BSD-3-Clause |
| 5 | compatibility Requires Python 3.10+ with openpiv installed (uv pip install openpiv). numpy, scipy, scikit-image, and matplotlib arrive as dependencies. No network access needed after install. |
| 6 | allowed-tools Read Write Edit Bash |
| 7 | metadata |
| 8 | version "1.1" |
| 9 | skill-author OpenPIV Team |
| 10 | tested-against "openpiv 0.25.4" |
| 11 | |
| 12 | |
| 13 | # OpenPIV |
| 14 | |
| 15 | ## Overview |
| 16 | |
| 17 | OpenPIV (Open Particle Image Velocimetry) analyzes fluid flow from PIV image pairs. It covers |
| 18 | preprocessing, cross-correlation, vector validation, outlier replacement, smoothing, and scaling to |
| 19 | physical units. |
| 20 | |
| 21 | Everything below is verified against **openpiv 0.25.4**. The API moves between releases — check |
| 22 | `inspect.signature()` before trusting a snippet against a different version. |
| 23 | |
| 24 | ## When to use |
| 25 | |
| 26 | Use this skill when working with experimental PIV or flow-visualization image pairs: measuring 2D |
| 27 | velocity fields, tuning interrogation-window parameters, validating vectors, or deriving vorticity, |
| 28 | strain rate, and turbulence statistics. For *simulating* flow rather than measuring it, use a CFD |
| 29 | skill instead. |
| 30 | |
| 31 | ## Quick Start |
| 32 | |
| 33 | Install OpenPIV: |
| 34 | |
| 35 | |
| 36 | uv pip install openpiv |
| 37 | |
| 38 | # Pin it when the analysis needs to be reproducible -- this is the version every |
| 39 | # snippet below was checked against. |
| 40 | uv pip install "openpiv==0.25.4" |
| 41 | |
| 42 | |
| 43 | Run PIV analysis on an image pair: |
| 44 | |
| 45 | |
| 46 | import numpy as np |
| 47 | from openpiv import tools, pyprocess, validation, filters, scaling |
| 48 | |
| 49 | frame_a = tools.imread("image_a.bmp") |
| 50 | frame_b = tools.imread("image_b.bmp") |
| 51 | |
| 52 | # Cross-correlate. Returns (u, v, s2n) whenever sig2noise_method is not None. |
| 53 | u, v, s2n = pyprocess.extended_search_area_piv( |
| 54 | frame_a.astype(np.int32), |
| 55 | frame_b.astype(np.int32), |
| 56 | window_size=32, |
| 57 | overlap=12, |
| 58 | dt=0.02, |
| 59 | search_area_size=38, |
| 60 | correlation_method="linear", # required for search_area_size > window_size |
| 61 | sig2noise_method="peak2peak", |
| 62 | ) |
| 63 | |
| 64 | x, y = pyprocess.get_coordinates( |
| 65 | image_size=frame_a.shape, |
| 66 | search_area_size=38, |
| 67 | overlap=12, |
| 68 | ) |
| 69 | |
| 70 | # flags is a boolean array: True marks a spurious vector. |
| 71 | flags = validation.sig2noise_val(s2n, threshold=1.05) |
| 72 | u, v = filters.replace_outliers(u, v, flags, method="localmean", max_iter=3, kernel_size=2) |
| 73 | |
| 74 | # Scale to physical units, then flip to image coordinates for plotting. |
| 75 | x, y, u, v = scaling.uniform(x, y, u, v, scaling_factor=96.52) |
| 76 | x, y, u, v = tools.transform_coordinates(x, y, u, v) |
| 77 | |
| 78 | tools.save("vectors.txt", x, y, u, v, flags) |
| 79 | |
| 80 | |
| 81 | Or use the bundled CLI, which wraps exactly that pipeline: |
| 82 | |
| 83 | |
| 84 | python skills/openpiv/scripts/runner.py \ |
| 85 | --image frame_a.bmp --image frame_b.bmp --output_dir results --verbose |
| 86 | |
| 87 | |
| 88 | ## Core Concepts |
| 89 | |
| 90 | ### PIV Fundamentals |
| 91 | |
| 92 | Particle Image Velocimetry is an optical method for measuring fluid velocity by tracking illuminated |
| 93 | tracer particles between two images. |
| 94 | |
| 95 | **Process flow:** |
| 96 | |
| 97 | Capture an image pair (`frame_a`, `frame_b`) separated by a known time `dt`. |
| 98 | Divide the images into interrogation windows. |
| 99 | Cross-correlate matching windows to find peak displacement. |
| 100 | Validate vectors (signal-to-noise, global range, local median). |
| 101 | Replace spurious vectors with interpolated values. |
| 102 | Scale pixel displacements to physical units. |
| 103 | |
| 104 | ### Interrogation Window Parameters |
| 105 | |
| 106 | **`window_size`** — correlation window in pixels (typically 16–128). Larger windows give better |
| 107 | correlation but coarser spatial resolution. |
| 108 | |
| 109 | **`overlap`** — pixels shared between adjacent windows (typically 50–75% of `window_size`). Higher |
| 110 | overlap raises vector density and cost, but adjacent vectors become correlated rather than |
| 111 | independent. |
| 112 | |
| 113 | **`search_area_size`** — the window searched in the second frame. Must be ≥ `window_size`; a few |
| 114 | pixels larger accommodates larger displacements. Pair an extended search area with |
| 115 | `correlation_method="linear"` — the default `"circular"` relies on FFT wrap-around and aliases large |
| 116 | displacements into small ones. See `references/advanced_algorithms.md`. |
| 117 | |
| 118 | Rules of thumb: keep the largest displacement under about a quarter of `window_size`, and aim for |
| 119 | 5–10 particles per window. |
| 120 | |
| 121 | ### Signal-to-Noise Ratio |
| 122 | |
| 123 | `s2n` measures how distinct the correlation peak is. `sig2noise_method` controls how it is computed — |
| 124 | `"peak2mean"` (the function default) or `"peak2peak"`. **The two are on different scales**, so a |
| 125 | threshold tuned for one is meaningless for the other. Typical `peak2peak` thresholds are 1.05–1.3. |
| 126 | |
| 127 | |
| 128 | flags = validation.sig2noise_val(s2n, threshold=1.05) |
| 129 | # flags is bool: True == spurious. `~flags` selects the good vectors. |
| 130 | |
| 131 | |
| 132 | ## Common Operations |
| 133 | |
| 134 | ### Dynamic Masking |
| 135 | |
| 136 | Masking lives in `openpiv.preprocess`, **not** in an `openpiv.masking` module. It returns an |
| 137 | `(image, mask)` tuple and expects a float image. |
| 138 | |
| 139 | |
| 140 | from openpiv import preprocess |
| 141 | |
| 142 | # method="edges" for dark, sharp-edged objects; "intensity" for high-contrast objects. |
| 143 | frame_a_masked, mask_a = preprocess.dynamic_masking( |
| 144 | frame_a.astype(np.float64), method="intensity", filter_size=7, threshold=0.005 |
| 145 | ) |
| 146 | frame_b_masked, mask_b = preprocess.dynamic_masking( |
| 147 | frame_b.astype(np.float64), method="intensity", filter_size=7, threshold=0.005 |
| 148 | ) |
| 149 | |
| 150 | |
| 151 | Feed the **returned image** into the correlation step — it already has the masked region zeroed. Do |
| 152 | not multiply the original frame by `mask`: masking is already applied, and for `method="edges"` the |
| 153 | mask comes back as `uint8` 0/255 rather than boolean, so multiplying rescales the image by 255. |
| 154 | |
| 155 | ### Multi-Pass Processing |
| 156 | |
| 157 | Multi-pass (window deformation) lives in `openpiv.windef`, driven by a `PIVSettings` dataclass. |
| 158 | `pyprocess` has no multi-pass entry point. |
| 159 | |
| 160 | |
| 161 | import numpy as np |
| 162 | from openpiv import scaling, windef |
| 163 | |
| 164 | settings = windef.PIVSettings() |
| 165 | settings.windowsizes = (64, 32, 16) # one entry per pass, decreasing (this is also the default) |
| 166 | settings.overlap = (32, 16, 8) # same length as windowsizes |
| 167 | settings.num_iterations = 3 # number of passes to actually run |
| 168 | settings.sig2noise_threshold = 1.05 |
| 169 | |
| 170 | x, y, u, v, flags = windef.simple_multipass( |
| 171 | frame_a.astype(np.int32), frame_b.astype(np.int32), settings |
| 172 | ) |
| 173 | |
| 174 | # Output is in PIXELS PER FRAME -- convert yourself. scaling.uniform only divides |
| 175 | # by scaling_factor, so apply dt separately. |
| 176 | dt = 0.02 |
| 177 | x, y, u, v = scaling.uniform(x, y, u, v, scaling_factor=96.52) |
| 178 | u, v = u / dt, v / dt |
| 179 | |
| 180 | |
| 181 | `simple_multipass` already validates, replaces outliers, fills remaining NaNs with zeros, and calls |
| 182 | `transform_coordinates` — do not repeat those steps. |
| 183 | |
| 184 | **Units trap:** `PIVSettings` has `dt` and `scaling_factor` fields, but `windef` never uses either — |
| 185 | `first_pass` calls `extended_search_area_piv` without `dt`, so the whole multi-pass chain works in |
| 186 | pixels per frame. Setting `settings.dt = 0.02` changes nothing about the returned values. Convert |
| 187 | after the fact, as above. |
| 188 | |
| 189 | For control over individual passes, `windef.first_pass` and `windef.multipass_img_deform` are the |
| 190 | lower-level building blocks. |
| 191 | |
| 192 | ## Validation and Post-Processing |
| 193 | |
| 194 | ### Validation Methods |
| 195 | |
| 196 | Every validator returns a boolean array where **True marks a spurious vector**. |
| 197 | |
| 198 | |
| 199 | # Signal-to-noise |
| 200 | flags = validation.sig2noise_val(s2n, threshold=1.05) |
| 201 | |
| 202 | # Global range -- takes (min, max) TUPLES, positionally or as u_thresholds/v_thresholds. |
| 203 | flags = validation.global_val(u, v, (-300, 300), (-300, 300)) |
| 204 | |
| 205 | # Local median -- u_threshold and v_threshold are REQUIRED; size is the neighbourhood half-width. |
| 206 | flags = validation.local_median_val(u, v, u_threshold=30.0, v_threshold=30.0, size=1) |
| 207 | |
| 208 | # Combine with boolean OR (not np.maximum -- these are bool arrays). |
| 209 | flags = ( |
| 210 | validation.sig2noise_val(s2n, threshold=1.05) |
| 211 | | validation.global_val(u, v, (-300, 300), (-300, 300)) |
| 212 | | validation.local_median_val(u, v, u_threshold=30.0, v_threshold=30.0) |
| 213 | ) |
| 214 | |
| 215 | |
| 216 | **Set these thresholds in the units of `u` and `v`, not in pixels per frame.** |
| 217 | `extended_search_area_piv` divides by `dt`, so with `dt=0.02` a 3 px/frame displacement arrives as |
| 218 | 150 px/s. The thresholds above suit that case; the `(-30, 30)` figure that PIV literature and |
| 219 | `PIVSettings.min_max_u_disp` use is a px/frame limit, and applying it to px/s output rejects the |
| 220 | entire field. Either validate before scaling, or scale the thresholds by `1/dt` too. |
| 221 | |
| 222 | ### Outlier Replacement |
| 223 | |
| 224 | |
| 225 | u, v = filters.replace_outliers( |
| 226 | u, v, flags, method="localmean", max_iter=3, tol=1e-3, kernel_size=2 |
| 227 | ) |
| 228 | |
| 229 | |
| 230 | `method` accepts `"localmean"`, `"disk"`, or `"distance"` — and only those three. An unrecognized |
| 231 | name is not rejected; it falls through to an all-zero kernel and silently returns a useless field. |
| 232 | Note that replacement *fills* the flagged |
| 233 | positions with interpolated values — if you then overwrite them with NaN, the replacement was |
| 234 | wasted. Choose one or the other: |
| 235 | |
| 236 | |
| 237 | # Keep flagged vectors out of the analysis entirely, instead of interpolating them. |
| 238 | u = np.where(flags, np.nan, u) |
| 239 | v = np.where(flags, np.nan, v) |
| 240 | |
| 241 | |
| 242 | ### Smoothing |
| 243 | |
| 244 | Smoothing is `openpiv.smoothn.smoothn`; there is no `openpiv.smooth` module. It returns a tuple |
| 245 | whose first element is the smoothed field, and it does not accept NaN input. |
| 246 | |
| 247 | |
| 248 | from openpiv.smoothn import smoothn |
| 249 | |
| 250 | u_smooth, *_ = smoothn(np.nan_to_num(u), s=0.5) # s: larger == smoother |
| 251 | v_smooth, *_ = smoothn(np.nan_to_num(v), s=0.5) |
| 252 | u_smooth = np.asarray(u_smooth) |
| 253 | |
| 254 | |
| 255 | ## Visualization |
| 256 | |
| 257 | ### Vector Field Plotting |
| 258 | |
| 259 | `display_vector_field` reads a saved vectors file and calls `plt.show()` internally, so select a |
| 260 | non-interactive backend for batch runs. |
| 261 | |
| 262 | |
| 263 | import matplotlib |
| 264 | matplotlib.use("Agg") |
| 265 | import matplotlib.pyplot as plt |
| 266 | from openpiv import tools |
| 267 | |
| 268 | fig, ax = plt.subplots(figsize=(8, 8)) |
| 269 | tools.display_vector_field( |
| 270 | "vectors.txt", |
| 271 | ax=ax, |
| 272 | scaling_factor=96.52, # same factor used in scaling.uniform, to map back onto the image |
| 273 | scale=50, |
| 274 | width=0.0035, |
| 275 | on_img=True, |
| 276 | image_name="frame_a.bmp", |
| 277 | ) |
| 278 | fig.savefig("vector_field.png", dpi=150, bbox_inches="tight") |
| 279 | plt.close(fig) |
| 280 | |
| 281 | |
| 282 | ### Custom Visualization |
| 283 | |
| 284 | |
| 285 | import numpy as np |
| 286 | import matplotlib.pyplot as plt |
| 287 | |
| 288 | fig, axes = plt.subplots(1, 3, figsize=(15, 5)) |
| 289 | |
| 290 | mag = np.sqrt(u**2 + v**2) |
| 291 | for ax, field, title, cmap in [ |
| 292 | (axes[0], mag, "Velocity Magnitude", "viridis"), |
| 293 | (axes[1], u, "U Velocity", "RdBu_r"), |
| 294 | (axes[2], v, "V Velocity", "RdBu_r"), |
| 295 | ]: |
| 296 | im = ax.imshow(field, cmap=cmap) |
| 297 | ax.set_title(title) |
| 298 | plt.colorbar(im, ax=ax) |
| 299 | |
| 300 | fig.tight_layout() |
| 301 | fig.savefig("velocity_components.png") |
| 302 | plt.close(fig) |
| 303 | |
| 304 | |
| 305 | ## Analysis Functions |
| 306 | |
| 307 | `scripts/analyze.py` bundles these against a `params.npz` written by `runner.py`. It infers the |
| 308 | physical grid spacing from the saved coordinates, so the derivatives come out per unit length: |
| 309 | |
| 310 | |
| 311 | import sys |
| 312 | sys.path.insert(0, "skills/openpiv/scripts") |
| 313 | from analyze import PIVAnalyzer |
| 314 | |
| 315 | piv = PIVAnalyzer("results/params.npz") |
| 316 | vorticity = piv.compute_vorticity() # dv/dx - du/dy |
| 317 | exx, eyy, exy = piv.compute_strain() |
| 318 | stats = piv.compute_statistics() # u_mean, v_mean, rms_u, rms_v, tke |
| 319 | piv.plot_vector_field(save_path="quiver.png") |
| 320 | |
| 321 | |
| 322 | The standalone forms, if you would rather compute them inline: |
| 323 | |
| 324 | ### Vorticity |
| 325 | |
| 326 | |
| 327 | def compute_vorticity(u, v, dx=1.0, dy=None): |
| 328 | """Out-of-plane vorticity dv/dx - du/dy. Pass the physical grid spacing, not 1.0.""" |
| 329 | dy = dx if dy is None else dy |
| 330 | return np.gradient(v, dx, axis=1) - np.gradient(u, dy, axis=0) |
| 331 | |
| 332 | |
| 333 | The grid spacing is `(window_size - overlap) / scaling_factor` in physical units, so leaving `dx=1.0` |
| 334 | yields vorticity per grid cell, not per unit length. |
| 335 | |
| 336 | **Sign convention:** `runner.py` ends with `transform_coordinates`, which relabels the grid into a |
| 337 | right-handed y-up frame but leaves the rows in image order, so the saved `y` *decreases* as the row |
| 338 | index grows. The standalone forms above assume the opposite, so on a `params.npz` field they return |
| 339 | `-du/dy` and flip the sign of the vorticity and the shear strain — negate the `axis=0` derivatives, or |
| 340 | use `PIVAnalyzer`, which reads the orientation off the saved coordinates. |
| 341 | |
| 342 | ### Strain Rate |
| 343 | |
| 344 | |
| 345 | def compute_strain(u, v, dx=1.0, dy=None): |
| 346 | """Return (exx, eyy, exy) of the 2D strain-rate tensor.""" |
| 347 | dy = dx if dy is None else dy |
| 348 | du_dx = np.gradient(u, dx, axis=1) |
| 349 | du_dy = np.gradient(u, dy, axis=0) |
| 350 | dv_dx = np.gradient(v, dx, axis=1) |
| 351 | dv_dy = np.gradient(v, dy, axis=0) |
| 352 | return du_dx, dv_dy, 0.5 * (du_dy + dv_dx) |
| 353 | |
| 354 | |
| 355 | ### Turbulence Statistics |
| 356 | |
| 357 | |
| 358 | def compute_statistics(u, v): |
| 359 | """Single-frame spatial statistics. NOT Reynolds decomposition.""" |
| 360 | u_prime = u - np.nanmean(u) |
| 361 | v_prime = v - np.nanmean(v) |
| 362 | rms_u, rms_v = np.nanstd(u_prime), np.nanstd(v_prime) |
| 363 | return { |
| 364 | "u_mean": np.nanmean(u), |
| 365 | "v_mean": np.nanmean(v), |
| 366 | "rms_u": rms_u, |
| 367 | "rms_v": rms_v, |
| 368 | "tke": 0.5 * (rms_u**2 + rms_v**2), |
| 369 | } |
| 370 | |
| 371 | |
| 372 | **Caveat:** subtracting the *spatial* mean of one frame measures spatial variance, which equals |
| 373 | turbulent intensity only for a homogeneous field. Genuine Reynolds decomposition needs an ensemble of |
| 374 | image pairs: average over the time axis, then subtract that mean field from each realization. |
| 375 | |
| 376 | ## CLI Usage |
| 377 | |
| 378 | |
| 379 | # Basic run |
| 380 | python skills/openpiv/scripts/runner.py \ |
| 381 | --image img1.bmp --image img2.bmp --output_dir results --verbose |
| 382 | |
| 383 | # Tuned parameters with dynamic masking |
| 384 | python skills/openpiv/scripts/runner.py \ |
| 385 | --image frame_a.bmp \ |
| 386 | --image frame_b.bmp \ |
| 387 | --output_dir results \ |
| 388 | --window_size 32 \ |
| 389 | --overlap 12 \ |
| 390 | --search_area 38 \ |
| 391 | --dt 0.02 \ |
| 392 | --scaling 96.52 \ |
| 393 | --threshold 1.05 \ |
| 394 | --mask dynamic \ |
| 395 | --mask_method intensity \ |
| 396 | --verbose |
| 397 | |
| 398 | |
| 399 | ### CLI Options |
| 400 | |
| 401 | | Option | Default | Description | |
| 402 | |--------|---------|-------------| |
| 403 | | `--image` | required | Image file; specify exactly twice for the pair | |
| 404 | | `--output_dir` | `results` | Output directory (created if absent) | |
| 405 | | `--window_size` | 32 | Interrogation window size (px) | |
| 406 | | `--overlap` | 12 | Window overlap (px) | |
| 407 | | `--search_area` | 38 | Search area size (px), must be ≥ `--window_size` | |
| 408 | | `--dt` | 0.02 | Time between frames (s) | |
| 409 | | `--scaling` | 96.52 | Scaling factor, pixels per physical unit (e.g. px/mm) | |
| 410 | | `--threshold` | 1.05 | `peak2peak` signal-to-noise threshold | |
| 411 | | `--mask` | `none` | `none` or `dynamic` (`openpiv.preprocess.dynamic_masking`) | |
| 412 | | `--mask_method` | `intensity` | `edges` or `intensity`, used only with `--mask dynamic` | |
| 413 | | `--drop_invalid` | off | NaN out flagged vectors instead of keeping interpolated values | |
| 414 | | `--verbose` | off | Print progress messages | |
| 415 | |
| 416 | Verify an install end to end against OpenPIV's own bundled image pair: |
| 417 | |
| 418 | |
| 419 | python skills/openpiv/scripts/run_example.py --output_dir /tmp/openpiv-demo |
| 420 | |
| 421 | |
| 422 | ## Output Files |
| 423 | |
| 424 | **vectors.txt** — tab-delimited, `%.4e` formatted, with a `# x y u v flags mask` comment header |
| 425 | **params.npz** — NumPy archive with `x`, `y`, `u`, `v`, `flags` arrays |
| 426 | **vector_field.png** — vector field drawn over the first frame |
| 427 | |
| 428 | |
| 429 | # x y u v flags mask |
| 430 | 2.1757e-01 3.5226e+00 -6.2220e-02 -2.7081e+00 0.0000e+00 0.0000e+00 |
| 431 | 4.8695e-01 3.5226e+00 -3.1587e-01 -2.9800e+00 0.0000e+00 0.0000e+00 |
| 432 | |
| 433 | |
| 434 | `flags` is written as a float, `0` for a valid vector and `1` for a flagged one. |
| 435 | |
| 436 | ## Best Practices |
| 437 | |
| 438 | ### Parameter Selection |
| 439 | |
| 440 | **Window size** — 32×32 suits most cases. 64/128 for better correlation at coarser resolution; |
| 441 | 16/24 for finer resolution at the cost of noise. |
| 442 | **Overlap** — 50–75% of window size. |
| 443 | **Threshold** — raise it to reject more vectors; always re-tune after switching |
| 444 | `sig2noise_method`. |
| 445 | **Scaling factor** — calibrate against a known reference such as a calibration grid, and keep the |
| 446 | units straight (`96.52` in OpenPIV's `test1` tutorial data is px/mm). |
| 447 | |
| 448 | ### Image Quality |
| 449 | |
| 450 | Particles visible and evenly distributed, 5–10 per interrogation window |
| 451 | No saturated or overexposed regions |
| 452 | Minimal background noise; consider background subtraction across a run |
| 453 | |
| 454 | ### Processing Tips |
| 455 | |
| 456 | Start from the defaults, then tune against the vector field you get. |
| 457 | Inspect the `s2n` distribution — a low median means poor correlation, not a bad threshold. |
| 458 | Visualize early; obvious problems (uniform vectors, edge artifacts) show up immediately. |
| 459 | Use multi-pass (`windef`) for flows with large velocity gradients or displacements. |
| 460 | Mask reflections and solid boundaries rather than letting them generate vectors. |
| 461 | |
| 462 | ## Resources |
| 463 | |
| 464 | ### references/ |
| 465 | |
| 466 | `advanced_algorithms.md` — correlation and subpixel methods, multi-pass window deformation, |
| 467 | `PIVSettings` fields, 3D and phase-separation modules |
| 468 | |
| 469 | Load the reference when detailed algorithm or settings information is needed. |
| 470 |
Details
- Updated
- Sep 21, 2026
- License
- MIT
- Stars on the repo
- ★ 45,977
- Checked
- Source
- K-Dense-AI/scientific-agent-skills ↗
- Creator
- K-Dense-AI · 168 listings
Similar skills
See all → SkillCore Python library for astronomy and astrophysics workflowsAstropy
 K-Dense-AI/scientific-agent-skills · by K-Dense-AICore Python library for astronomy and astrophysics workflows that need Astropy APIs, including units/quantities, coordinates, FITS I/O, tables, time systems, WCS, and cosmology. Use when implementing or debugging astronomical data analysis code with Astropy.★ 46k GitHub stars
 SkillGoogle quantum computing frameworkCirq - Quantum Computing with PythonK-Dense-AI/scientific-agent-skills · by K-Dense-AIGoogle quantum computing framework. Use when targeting Google Quantum AI hardware, designing noise-aware circuits, or running quantum characterization experiments. Best for Google hardware, noise modeling, and low-level circuit design. For IBM hardware use qiskit; for quantum ML with autodiff use pennylane; for physics simulations use qutip.★ 46k GitHub stars
 SkillPlan, configure, inspect, restartFluidsimK-Dense-AI/scientific-agent-skills · by K-Dense-AIPlan, configure, inspect, restart, and analyze bounded FluidSim computational-fluid-dynamics simulations with explicit numerical-validity and HPC safety checks. Use for FluidSim solver selection, parameter review, FFT/MPI setup, output diagnostics, or restart compatibility.★ 46k GitHub stars
 SkillHardware-agnostic quantum ML framework with automaticPennylaneK-Dense-AI/scientific-agent-skills · by K-Dense-AIHardware-agnostic quantum ML framework with automatic differentiation. Use when training quantum circuits via gradients, building hybrid quantum-classical models, or needing device portability across IBM/Google/Rigetti/IonQ. Best for variational algorithms (VQE, QAOA), quantum neural networks, and integration with PyTorch or JAX. For hardware-specific optimizations use qiskit (IBM) or cirq (Google); for open quantum systems use qutip.★ 46k GitHub stars
 SkillVersion-aware guidance for PufferLib reinforcement-learningK-Dense-AI/scientific-agent-skills · by K-Dense-AIVersion-aware guidance for PufferLib reinforcement-learning environments, vectorization, policies, PuffeRL training, evaluation, and safe checkpoint review. Use when adapting Gymnasium/PettingZoo environments to published PufferLib 3.0.0 or working with the redesigned native 4.0 source line.★ 46k GitHub stars
 SkillBuild, simulate, transpileQiskitK-Dense-AI/scientific-agent-skills · by K-Dense-AIBuild, simulate, transpile, and execute quantum circuits with Qiskit and IBM Quantum Runtime. Use for Qiskit 2.x circuits and operators, V2 Sampler or Estimator primitives, target-aware transpilation, local or noisy simulation, IBM QPU execution, Runtime sessions or batches, error mitigation, and Qiskit ecosystem packages.★ 46k GitHub stars
More from K-Dense-AI
 SkillHow to use the Adaptyv Bio Foundry API and Python SDKK-Dense-AI/scientific-agent-skills · by K-Dense-AIHow to use the Adaptyv Bio Foundry API and Python SDK for protein experiment design, submission, and results retrieval. Use this skill whenever the user mentions Adaptyv, Foundry API, protein binding assays, protein screening experiments, BLI/SPR assays, thermostability assays, or wants to submit protein sequences for experimental characterization. Also trigger when code imports `adaptyv`, `adaptyv_sdk`, or `FoundryClient`, or references `foundry-api-public.adaptyvbio.com`.★ 46k GitHub stars
 SkillAeon Time Series Machine LearningK-Dense-AI/scientific-agent-skills · by K-Dense-AIThis skill should be used for time series machine learning tasks including classification, regression, clustering, forecasting, anomaly detection, segmentation, and similarity search. Use when working with temporal data, sequential patterns, or time-indexed observations requiring specialized algorithms beyond standard ML approaches. Particularly suited for univariate and multivariate time series analysis with scikit-learn compatible APIs.★ 46k GitHub stars
 SkillPlan, execute, and document validation, verificationAnalytical method validationK-Dense-AI/scientific-agent-skills · by K-Dense-AIPlan, execute, and document validation, verification, and transfer of analytical procedures under the governing framework - ICH Q2(R2) and Q14, USP <1220>/<1225>/<1226>, ICH M10 bioanalytical, CLSI EP, or ISO/IEC 17025. Use for HPLC, LC-MS/MS, GC, CE, ICP-MS, dissolution, qNMR, qPCR, NIR, and ligand binding or cell-based assays whenever the question is whether a procedure is fit for its intended purpose. Triggers include "method validation", "analytical method validation", "AMV", "validation protocol", "acceptance criteria", "linearity", "reportable range", "accuracy and precision", "repeatability", "intermediate precision", "recovery", "LOD", "LOQ", "detection limit", "quantitation limit", "specificity", "robustness", "method transfer", "method comparison", "Deming", "Passing-Bablok", "Bland-Altman", "equivalence testing", "OOS investigation", "ICH Q2", "Q2(R2)", "Q14", "USP 1225", "ICH M10", "incurred sample reanalysis", "ISR", "CLSI EP", and any request to show that an assay works.★ 46k GitHub stars
 SkillData structure for annotated matrices in single-cellAnndataK-Dense-AI/scientific-agent-skills · by K-Dense-AIData structure for annotated matrices in single-cell analysis. Use when working with .h5ad files or integrating with the scverse ecosystem. This is the data format skill—for analysis workflows use scanpy; for probabilistic models use scvi-tools; for population-scale queries use cellxgene-census.★ 46k GitHub stars
 SkillAutonomously improve a real artifact against an objectiveArbor — Autonomous Optimization via Hypothesis Tree RefinementK-Dense-AI/scientific-agent-skills · by K-Dense-AIAutonomously improve a real artifact (code, training recipe, agent harness, data pipeline, prompt) against an objective and an evaluator, using Hypothesis Tree Refinement (HTR) from the Arbor paper. Use this whenever someone wants to iteratively optimize something over many experiments without overfitting — e.g. "get my model's eval score up", "improve this agent/harness", "tune this pipeline", "beat the baseline on this benchmark", "run a search over approaches and keep the best", "do an MLE-bench / Kaggle-style optimization", or any long-horizon "make this artifact better and don't just memorize the dev set" task. Trigger it even when the user doesn't say "Arbor" or "hypothesis tree" but describes repeated experiment-and-evaluate loops, branching exploration of competing ideas, or worries about a dev/test gap. Runs Claude itself as the coordinator with subagent executors in isolated git worktrees; for the standalone `arbor` CLI tool see references/arbor-upstream.md.★ 46k GitHub stars
 SkillInfer gene regulatory networks from gene expression dataArboretoK-Dense-AI/scientific-agent-skills · by K-Dense-AIInfer gene regulatory networks (GRNs) from gene expression data using scalable algorithms (GRNBoost2, GENIE3). Use when analyzing transcriptomics data (bulk RNA-seq, single-cell RNA-seq) to identify transcription factor-target gene relationships and regulatory interactions. Supports distributed computation for large-scale datasets.★ 46k GitHub stars